What Does Figure CEO Brett Adcock’s Version 3 Robot Teaser Reveal?
TL;DR
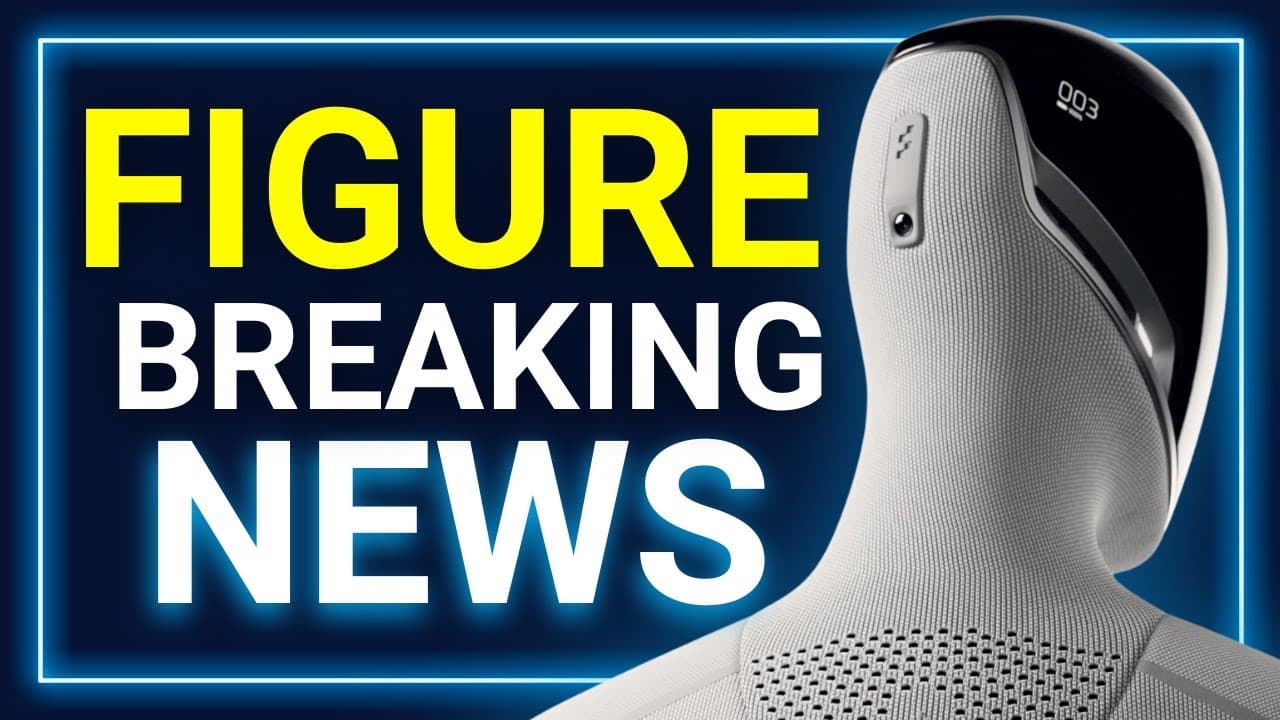
Figure’s version 3 humanoid robot teaser reveals a palm camera, a soft fabric exterior covering pinch points, redesigned hips, cooling vents, and inductive charging through the feet. Robotics expert Dr. Scott Walter estimates that the linkage-driven hand retains about 16 degrees of freedom, while noting that several specifications remain unconfirmed. Read on for a feature-by-feature explanation of what these changes could mean.
Transcript
Okay, welcome everybody. So, breaking news. Just a few hours ago, humanoid robot company Figure dropped a new demo of their version three humanoid robot figure. CEO Brett Adcock said that uh wait until Thursday. That's when they're going to actually do the actual reveal. We will watch this uh teaser demo right now. And uh he's saying that it's the ... Read More
Key Insights
- Figure’s version 3 exterior is covered with soft fabric that makes the robot look less mechanical while shielding joints and pinch points. The covering appears especially relevant around the shoulders, hips, elbows, wrists, and hands, where exposed mechanisms could catch objects or admit debris.
- A camera is built into the robot’s palm, giving the manipulation system a direct view of areas that may be hidden from head-mounted cameras. This could reduce dependence on touch sensing when grasping or handling objects, although the teaser also suggests that fingertip sensing may remain part of the design.
- The hand is estimated to retain about 16 degrees of freedom, but the teaser does not confirm whether finger abduction is supported. The expert believes it uses linkages rather than tendons, with actuators packaged inside the palm, and expects definitive specifications during the announced full reveal.
- The glove covering is designed to conceal openings that emerge around mechanical knuckles during finger movement. Keeping those areas covered can reduce pinch points, snag hazards, and the chance that dust or debris enters the hand while preserving a softer external surface.
- The head appears to include a rear camera, another camera near the chin, cameras behind the front screen, and a battery-status readout. It can also pan and tilt, while the distributed camera arrangement may expand visibility around the robot during movement and manipulation.
- The hip structure appears more compact and slightly angled downward, which may improve internal packaging and bring the legs closer together. The expert also identifies vents in several locations, including possible ventilation behind elbow fabric, to support airflow and cooling without obvious external obstructions.
- The robot may have an intrusion-protection design around the IP54 to IP56 range, but this is explicitly presented as an expert estimate rather than a confirmed specification. Such protection would address access by objects, dust or dirt exposure, and some degree of moisture contact.
- Inductive charging is shown in the foot, allowing the robot to receive power from a wireless mat while standing in an appropriate area. The expert expects this feature to provide convenient top-ups during stationary periods, while a conventional connection may remain available for faster charging.
Install to Summarize YouTube Videos and Get Transcripts
Explore YouTube Video Summarizer or Get YouTube Transcript Extractor
Questions & Answers
Q: What does Figure’s version 3 humanoid robot teaser reveal?
The teaser shows a softer fabric-covered exterior, a palm camera, possible fingertip sensors, redesigned shoulders and hips, multiple head cameras, cooling vents, flexible feet, and inductive charging through the feet. Dr. Scott Walter says the robot retains similarities to Figure 2 but includes many design improvements, while several specifications remain unconfirmed.
Q: Why does Figure’s humanoid robot have a camera in its palm?
The palm camera gives the robot a direct view of objects and contact areas that may be hidden from its head cameras. Dr. Walter says this could reduce reliance on touch sensing, although the fingertips also appear to contain additional sensors.
Q: How advanced is the hand in Figure’s version 3 robot teaser?
Dr. Walter estimates that it remains about a 16-degree-of-freedom hand with actuators built into the palm. He identifies it as a linkage-driven design rather than a tendon-driven hand, but says the teaser does not confirm whether it supports finger abduction.
Q: How does the fabric exterior improve Figure’s humanoid robot?
The fabric gives the robot a soft, less mechanical appearance and covers exposed pinch points. It also shields areas around joints and mechanical knuckles, while the removable garments appear easy to replace with other coverings.
Q: What cameras and displays appear on the robot’s head?
The head appears to have a rear camera, another camera near the chin, and cameras behind the front screen. It also includes readouts such as the battery-charge state, and the head can pan and tilt like Figure 2’s head.
Q: What changed in Figure’s version 3 hip design?
The hip design appears more compact and angles slightly downward. Dr. Walter says this arrangement may improve component packaging and bring the legs closer together instead of leaving them too widely spaced.
Q: How is Figure’s version 3 robot cooled?
The teaser shows vents in several locations that can help pull air through the robot without blocking airflow. Dr. Walter also suggests that the fabric behind the elbow may include ventilation, though that detail is not confirmed.
Q: How could inductive foot charging affect the robot’s runtime?
Inductive charging could let the robot receive power while standing on a compatible wireless mat. Dr. Walter expects it to provide convenient top-ups during stationary work or pauses, while conventional charging may remain available for faster charging and the wireless setup avoids a cable that could obstruct movement.
Summary & Key Takeaways
-
Figure’s teaser presents a version 3 humanoid robot with a softer, more humanlike exterior. Fabric and glove coverings conceal mechanical components and reduce exposed pinch or snag points. The expert also identifies changes around the shoulders, hips, hands, head, elbows, and feet, although the brief footage leaves several specifications uncertain.
-
The hands appear to use linkage mechanisms with actuators in the palms, alongside possible fingertip sensors and a clearly visible palm camera. The camera could let the robot observe objects or contact areas that its head cameras cannot see, reducing reliance on touch sensing while still allowing additional tactile sensing to support manipulation.
-
The foot display identifies inductive charging, suggesting the robot could receive power while standing or moving within a charging area. The expert expects this to supplement conventional faster charging rather than replace it. Frequent top-ups during pauses or stationary work could extend operating time without requiring a cable that might obstruct movement or create snag hazards.
Read in Other Languages (beta)
Share This Summary 📚
Summarize YouTube Videos and Get Video Transcripts with 1-Click
Try YouTube Summary with ChatGPT & Claude or YouTube Transcript Generator
Explore More Summaries from Brighter with Herbert 📚
Summarize YouTube Videos and Get Video Transcripts with 1-Click
Try YouTube Summary with ChatGPT & Claude or YouTube Transcript Generator